
NVIDIA Announces Latest Update for Isaac ROS SW
 Published2022.10.24 12:04
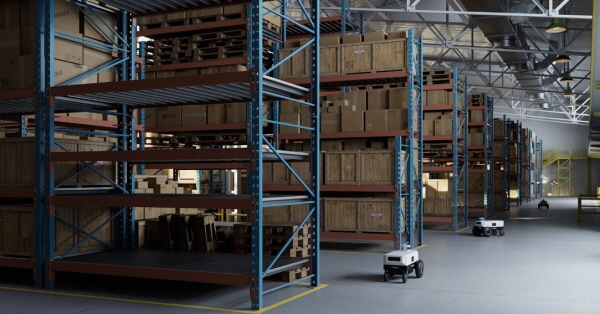
NVIDIA (CEO Jensen Huang), a leader in AI computing technology, has released a new robot operating system that provides open-source vehicle management tool capabilities for autonomous mobile robots.
NVIDIA announced on the 24th that it released Developer Preview (DP) 2, the latest Isaac Robotic Operating System (ROS) software release, at ROSCon 2022.
This release includes additional features for ROS 2 developers, as well as new cloud and edge-to-robot task management and monitoring software for autonomous mobile robot (AMR) fleets.
NVIDIA Isaac ROS consists of individual packages (GEM) and the entire pipeline (NITROS) for hardware acceleration performance.
In addition to performance improvements, the new release adds Mission Dispatch and Client, FreeSpace Segmentation, and H.264 video encoding and decoding capabilities.
Mission Dispatch and Client provide a standard open-source method for assigning and tracking tasks between a vehicle management system and a ROS 2 robot. Mission Dispatch and Client communicate using VDA5050, an open communication standard specifically designed for robot fleets. Messages are transmitted wirelessly via MQTT, a lightweight messaging protocol for Internet of Things (IoT) applications.
Isaac ROS continuously provides hardware acceleration performance to the ROS 2 developer community for AI recognition, image processing, and exploration.
Autonomous robots require advanced AI and computer vision capabilities. NVIDIA Isaac ROS is the result of efforts to enable the robotics industry to more easily adopt cutting-edge technology.
Detailed information on the latest performance figures for major Isaac ROS packages can be found in the Isaac ROS Performance Summary.
Comments
Related news
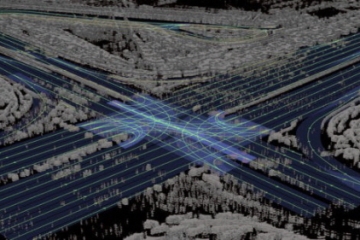
NVIDIA Unveils 'Drive Map', a Self-Driving Assistance Platform
Nvidia announced NVIDIA DRIVE Map, a multimodal mapping platform with stability and autonomy, during the GTC 2022 keynote.
2022.04.04by 성유창 기자
NVIDIA and Oracle Accelerate Enterprise AI Adoption
NVIDIA has announced on the 19th that it will collaborate with Oracle through a multi-year partnership to bring NVIDIA's complete accelerated computing stack—spanning from GPUs to systems and software—to Oracle Cloud Infrastructure (OCI).
2022.10.19by 김예지 기자
NVIDIA 'Hopper' Supports Meta Grand Teton Data Centers
Nvidia (CEO Jensen Huang), a leader in AI computing technology, is supporting Meta's data centers with its H100 GPU and addressing Meta's key artificial intelligence challenges.
2022.10.21by 배종인 기자
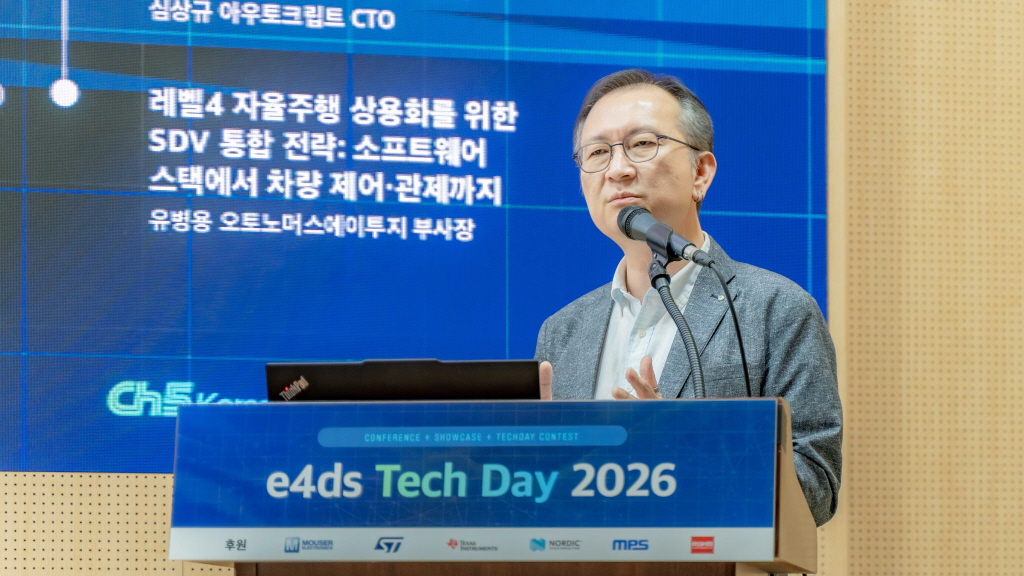
[e4ds Tech Day 2026 ⑨] Sim Sang-gyu, Autocrypt CTO: "In the Physical AI Era, Automotive Security Must Extend Beyond the Vehicle"
At e4ds Tech Day 2026, Sim Sang-gyu, CTO of Autocrypt, explained automotive cybersecurity strategies in the era of Physical AI and SDV (Software-Defined Vehicle). Automobiles are evolving as part of an ecosystem connected to AI, cloud, chargers, IoT, and robots, and he emphasized that the scope of security must expand beyond the vehicle interior to the entire connected environment. In particular, AI model tampering, adversarial attacks, OTA updates, and EV charger hacking were identified as major threats. He explained that response measures require zero trust, AI model integrity protection, intrusion detection, Security by Design and Default, and full lifecycle security management, and that proactive security system establishment beyond regulatory compliance is critical for securing future mobility competitiveness.
2026.10.12by 배종인 기자
Practical HIL Construction Strategy for Automotive and Off-Highway Controller Validation
As vehicle E/E architecture transitions to zonal structures and shifts to software-defined vehicles (SDV), the number of controllers (ECUs) requiring validation and software complexity are surging dramatically. Meanwhile, real vehicle testing cannot provide repeated verification under identical conditions and entails lead time and safety concerns. This white paper explains the principles of HIL (Hardware-in-the-Loop) validation and the structure of the NI platform composed of PXI, SLSC, and VeriStand, and through two actual implementation cases—Camera Record & Replay HIL for In-Cabin Monitoring Controller (ICMU) and Forklift Controller (VCU) HILS—describes how controller-level regression testing becomes possible. Additionally, it explicitly states application boundaries and limitations, such as lack of A2B support.
2026.10.12by 편집부