
Eclipse Cyclone DDS selected as ROS 2 Tier 1 Middleware
 Published2020.07.10 12:00
ROS 2 Foxy Fitzroy Tier 1 Middleware Selection
Development and implementation of industrial DDS, provision of professional services
ADLINK announced on the 9th that 'Eclipse Cyclone DDS', which was developed in collaboration with the Eclipse Foundation IoT Community, OpenADx Working Group, and ROS 2 Technical Steering Committee, has been selected as Tier 1 ROS 2 Middleware by the Open Source Robotics Foundation (OSRF).

Eclipse Cyclone DDS Selection [Image = ADLink]
ROS 2 Foxy Fitzroy is the first 3-year Long Term Support (LTS) version of ROS, and features improved performance and stability, with Eclipse Cyclone DDS as the underlying data sharing foundation for the RMW (ROS Middleware) layer.
Eclipse Cyclone DDS is a middleware that implements the Object Management Group (OMG) Data Distribution Service (DDS) for ROS 2, providing a platform for sharing data in a consistent and consistent manner.
“ROS 2 Foxy is a significant milestone in establishing a reference platform for large-scale robotics or autonomous vehicle applications,” said Dr. Angelo Corsaro, ADLINK’s CTO.“We are working to support the ROS 2 community and ecosystem with an open source DSS implementation,” he said.
Eclipse Cyclone DDS, hosted and supported by the Eclipse Foundation, is currently the fastest growing open source OMG DDS standard. ADLINK provides industrial version DDS development and implementation, as well as professional services. You can get started with Eclipse Cyclone DDS by visiting GitHub.
Comments
Related news

KT and Hyundai Robotics Partner to Grow Intelligent Robotics Business
KT announced that it has signed a business cooperation agreement and an investment contract worth 50 billion won for a strategic partnership with Hyundai Robotics. Through this, KT will secure a 10% stake in Hyundai Robotics. According to the contract, both companies plan to cooperate in the development of intelligent service robots, autonomous driving technology research, and smart factory sectors. KT will be responsible for software development and implementation related to intelligent service robots and autonomous driving technology, while Hyundai Robotics will handle hardware development and manufacturing.
2020.06.17by 명세환 기자
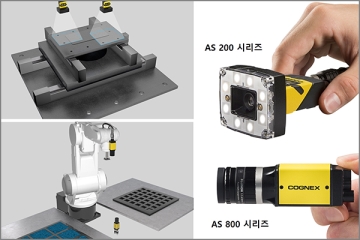
Cognex Unveils AlignSight, an All-in-One Industrial Vision Sensor
Cognex has announced the launch of the AlignSight Alignment Sensor Series, an integrated solution with the necessary features for vision-guided motion. AlignSight is a vision sensor solution for vision-guided robot and stage alignment applications, designed to enable easy and rapid setup of robot pick-and-place, machine tending, and stage motion in the electronics hardware industry.
2020.06.17by 이수민 기자
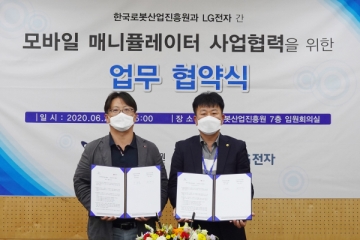
LG Electronics and KIRIA Enhance Safety of Industrial Autonomous Robots
LG Electronics and the Korea Robot Industry Promotion Agency have concluded a business agreement to enhance the safety of mobile manipulators. A mobile manipulator is a combination of a vertically articulated robot that performs movements similar to human arms and an autonomous mobile robot, which moves independently within factory production lines and other environments to perform various processes such as parts handling, product assembly, and inspection.
2020.06.30by 이수민 기자
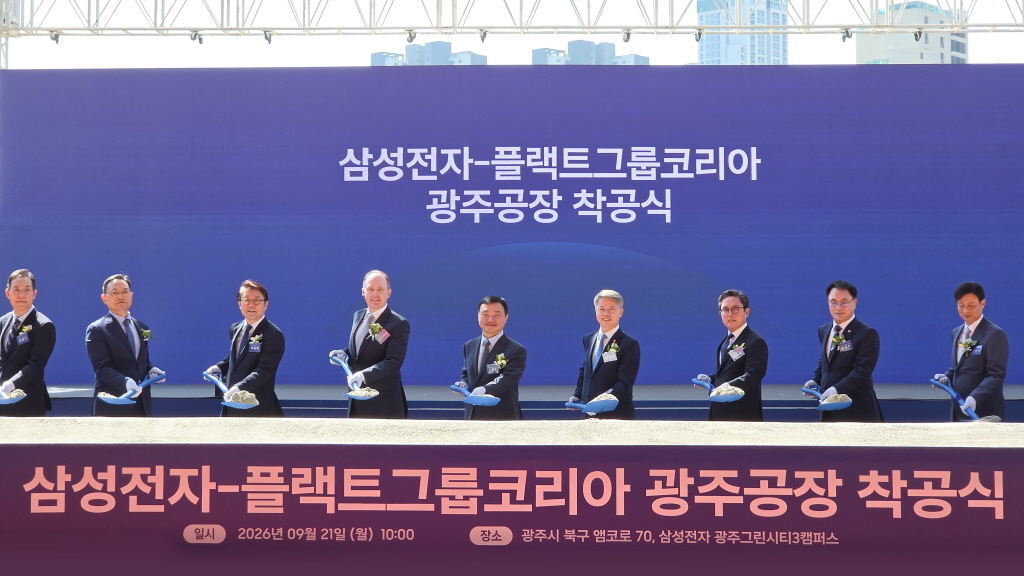
Samsung Electronics Breaks Ground on Flakt Group HVAC Production Line in Gwangju
Samsung Electronics has broken ground on an HVAC production line at its Gwangju facility in partnership with Flakt Group, with an investment of 240 billion won. The facility, spanning a gross floor area of 21,800 square meters, is targeted to commence operations in early 2028 and will manufacture core equipment such as CDUs and CRAHs to meet the rapidly increasing cooling and air conditioning demands of AI data centers and advanced manufacturing facilities.
2026.09.21by 명세환 기자
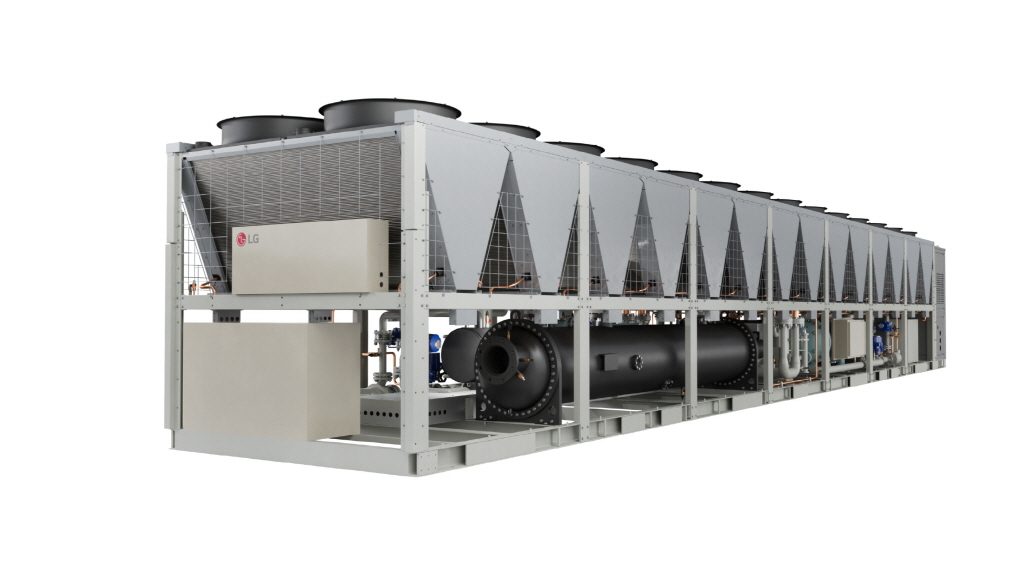
LG Electronics Launches Air-Cooled Turbo Chiller for AI Data Centers
LG Electronics has launched an air-cooled turbo chiller dedicated exclusively to AI data centers. By applying oil-free magnetic bearings and refrigerant free cooling technology, it increases operational efficiency by over 20% and reduces annual power consumption by 30%. The solution supports rapid deployment and flexible expansion through ISO standard container-based hydronic modular technology, while enhanced reliability is achieved through machine learning-based anomaly detection functionality.
2026.09.21by 명세환 기자