
 Real-time actuation loops are the key to next-generation mobility and robotics
 Published2026.07.09 17:15
Texas Instruments (TI) held the 'TI Mobility & Robotics Seminar 2026' at EL Tower on the 9th, where Heo Jung-hyuk, TI Director, presented on the topic of "Ethernet-based Real-time Actuation Loop for Next-generation Mobility and Robotics." He emphasized that the competitiveness of robots and next-generation mobility does not stem from simple motor performance, but rather from a real-time control architecture that integrates motor control, data communication, and functional safety into one unified system.
Related news
“Multi-protocol support motor solution, reducing hardware complexity and maximizing cost”
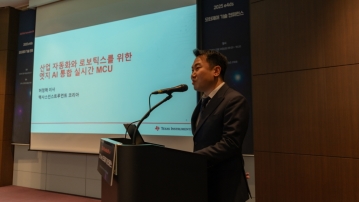
Heo Jeong-hyuk, Director at Texas Instruments (TI), presented on "Edge AI Real-time Control MCU Optimized for Motor Drive, Factory Automation, and Robotics" at the '2025 e4ds Motor Control Technology Conference' held at COEX in Samseong-dong, Seoul on March 14th. He argued that multi-protocol supported motor solutions capable of handling both motor control and communication functions in MCUs can reduce hardware complexity, shorten development time, and maximize cost efficiency.
2025.03.24by 배종인 기자

Humanoids: The Key is Motor Control and Power Efficiency
The key to humanoid robot design lies in precise internal systems rather than external appearance similar to humans. Technical documentation recently released by Texas Instruments (TI) emphasizes the importance of high-degree-of-freedom motor control, high-efficiency and compact design utilizing GaN-based power devices, and precision control through high-resolution current and voltage sensing. When combined with redundant architecture considering functional safety and fast shutdown design, a reliable robot capable of operating in shared spaces with humans can be completed.
2026.03.10by 배종인 기자

TI Supports Physical AI with Integrated Solution Encompassing Hardware and Software
Texas Instruments (TI) held a presentation at the 'e4ds Physical AI Frontier 2026' event, where Director Kim Tae-hoon discussed "Beyond the Cloud to Reality: Edge AI Solutions for Mobility and Industrial Applications." TI announced that it will support AI innovation in mobility and industrial environments through comprehensive solutions spanning both hardware and software.
2026.03.17by 배종인 기자

Next-generation magnetic sensors, Hall effect technology, are changing the game.
Smart door locks, notebooks, wireless earphones, and water/gas meters. Various electronic devices in our daily lives rely on invisible 'magnetic sensors' playing a crucial role, and among these, Hall effect-based in-plane magnetic sensors are emerging as a key sensing technology for next-generation electronic devices and smart infrastructure by simultaneously achieving miniaturization, low power consumption, and high reliability while surpassing the limitations of conventional reed switch and magnetoresistive technologies. In this context, according to a Technical Article titled "Hall Effect: How In-Plane Switches Increase Sensitivity and Reduce Design Costs" by Rishi Ramabadran recently released by Texas Instruments (TI), as miniaturization and low-power operation of electronic devices have accelerated in recent times, new solutions to replace existing magnetic switch technologies are drawing attention.
2026.03.19by 배종인 기자

TI Innovates Data Center and EV Design Paradigm with Next-Generation Isolated Power Modules
With power demand surging due to AI and electric vehicle proliferation, reliable power supply technology in limited spaces has emerged as a critical industry-wide challenge. Texas Instruments (TI) has unveiled the UCC34141-Q1 and UCC33420 high-performance isolated power modules, which employ proprietary packaging technology to address these requirements and establish a new direction for power design.
2026.03.24by 배종인 기자